01 / DRONESIn development
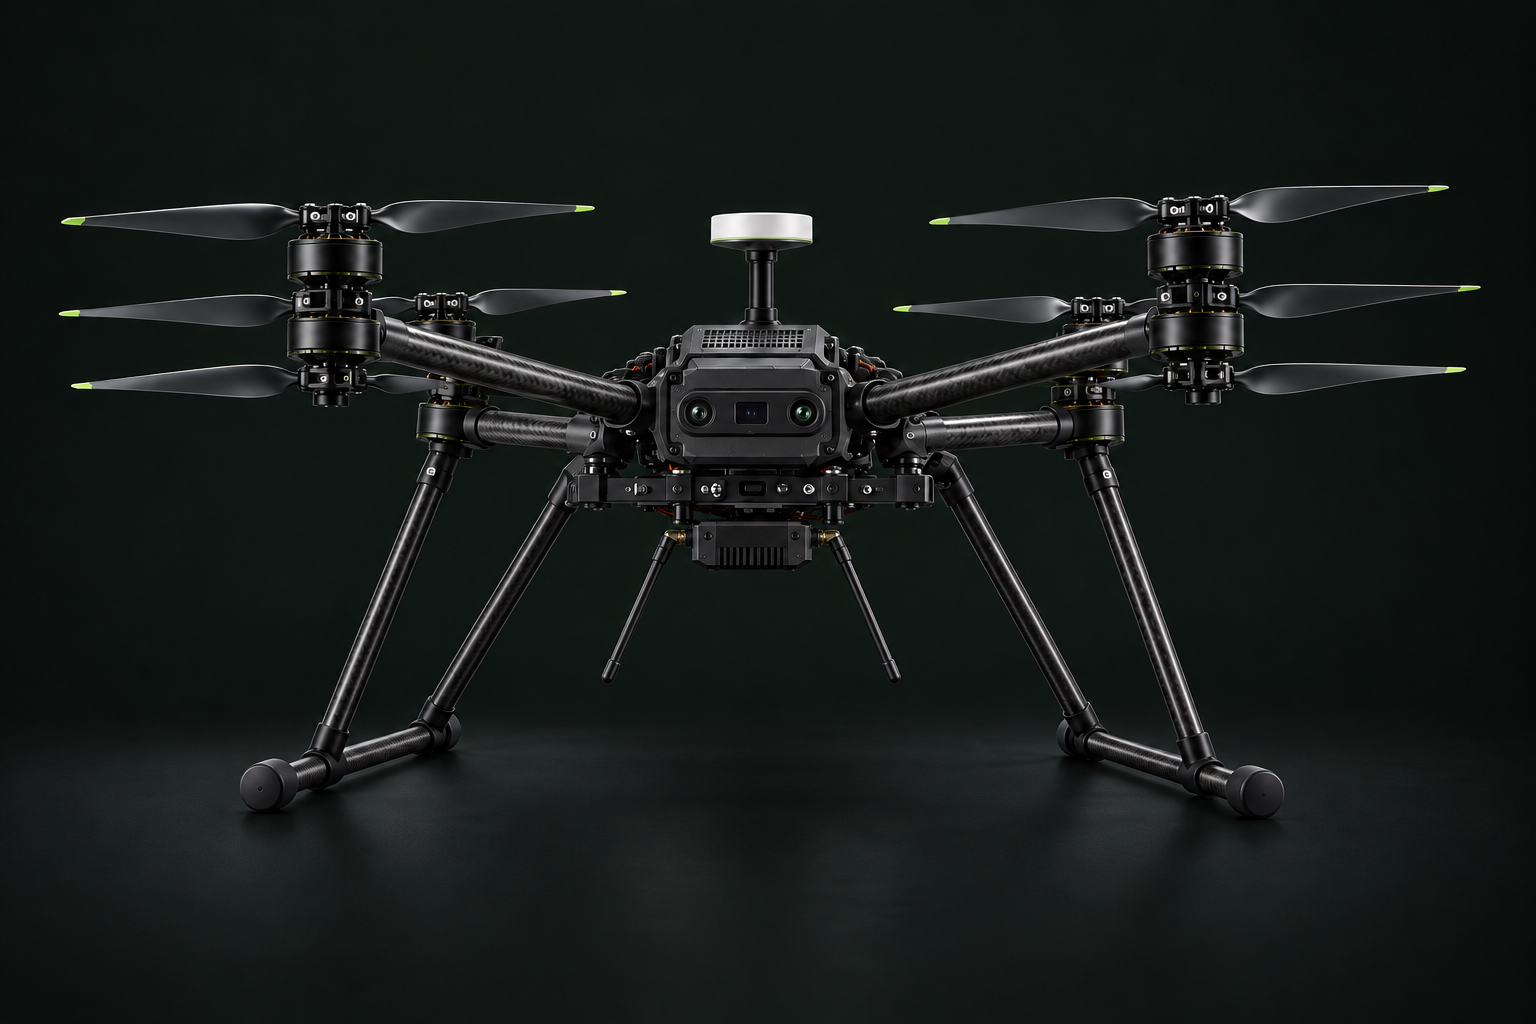
Aerqora Drones
Stacked X8 · wing-assisted direction
AERQORA / ROBOTICS + DRONES
Two platform tracks. Shared engineering.
Aevon OS as the proposed software foundation.
01 / THE PLATFORM FAMILY
Explore each platform with its own control, hardware and validation path.
Stacked X8 · wing-assisted direction
 ARMS / HANDS / MACHINES
Machines · arms · hands · mobile robots
| Design area | Drones | Robotics · proposed |
|---|---|---|
| Movement | Rotors · flight control | Joints / tools / wheels · motion control |
| Shared candidates | Perception · communications · interfaces | Perception · communications · interfaces |
| Platform-specific work | Airframe · propulsion · flight validation | Mechanisms · drives · contact / motion validation |
| Current scope | Aircraft concepts & module engineering | Product direction · no robot build claimed |
02 / THE CONNECTION
AI proposes. Deterministic control validates and acts. Timing and stop behavior need qualification on each target.
03 / SHARED BUILDING BLOCKS
Existing drone engineering provides candidates for reuse. Robotics compatibility remains to be tested.
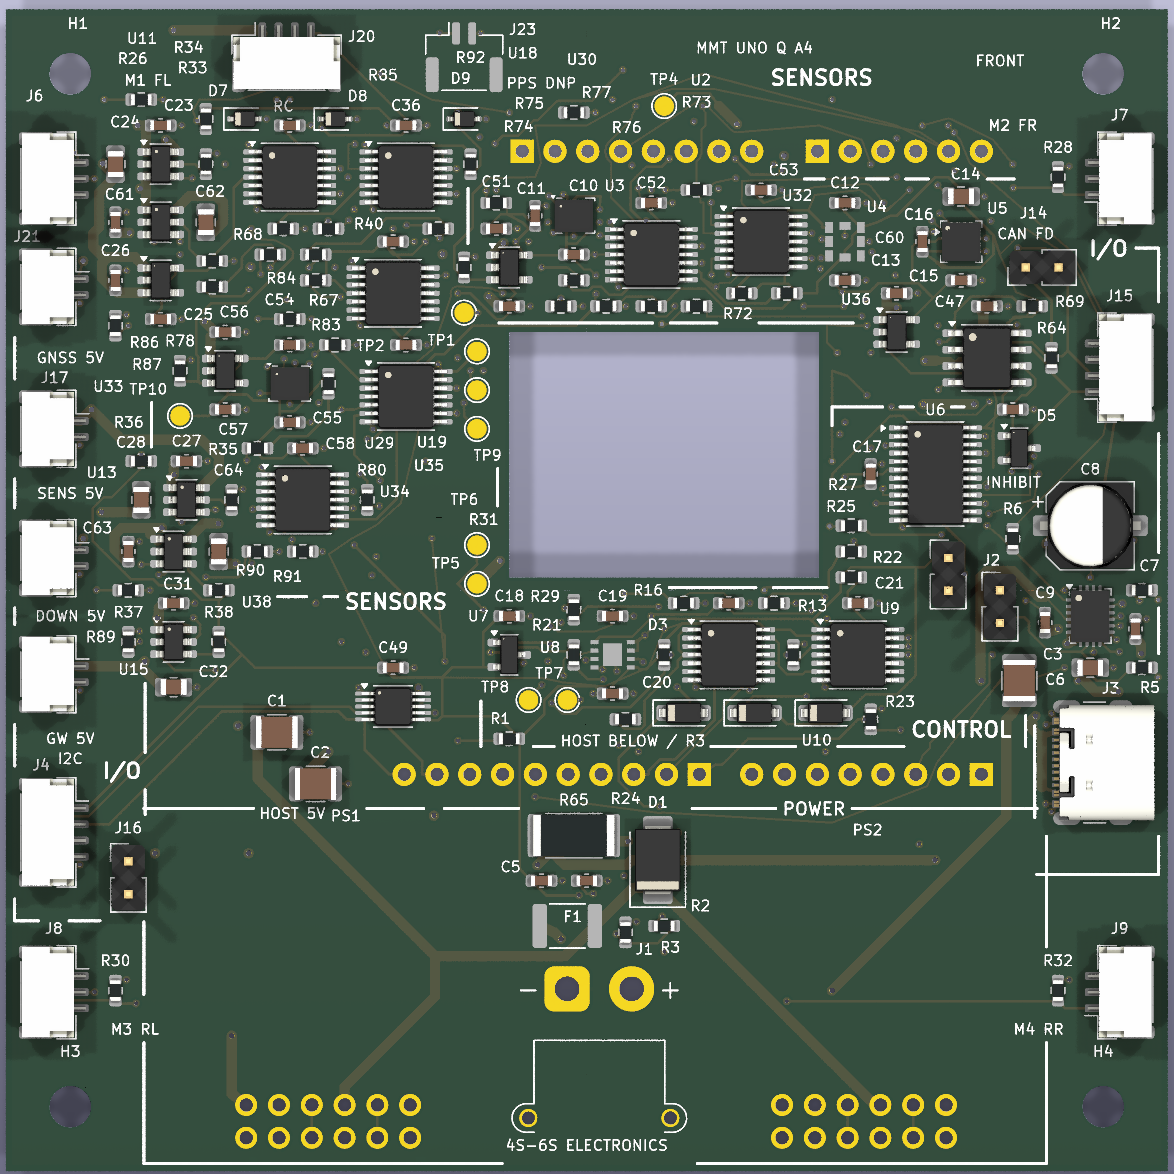
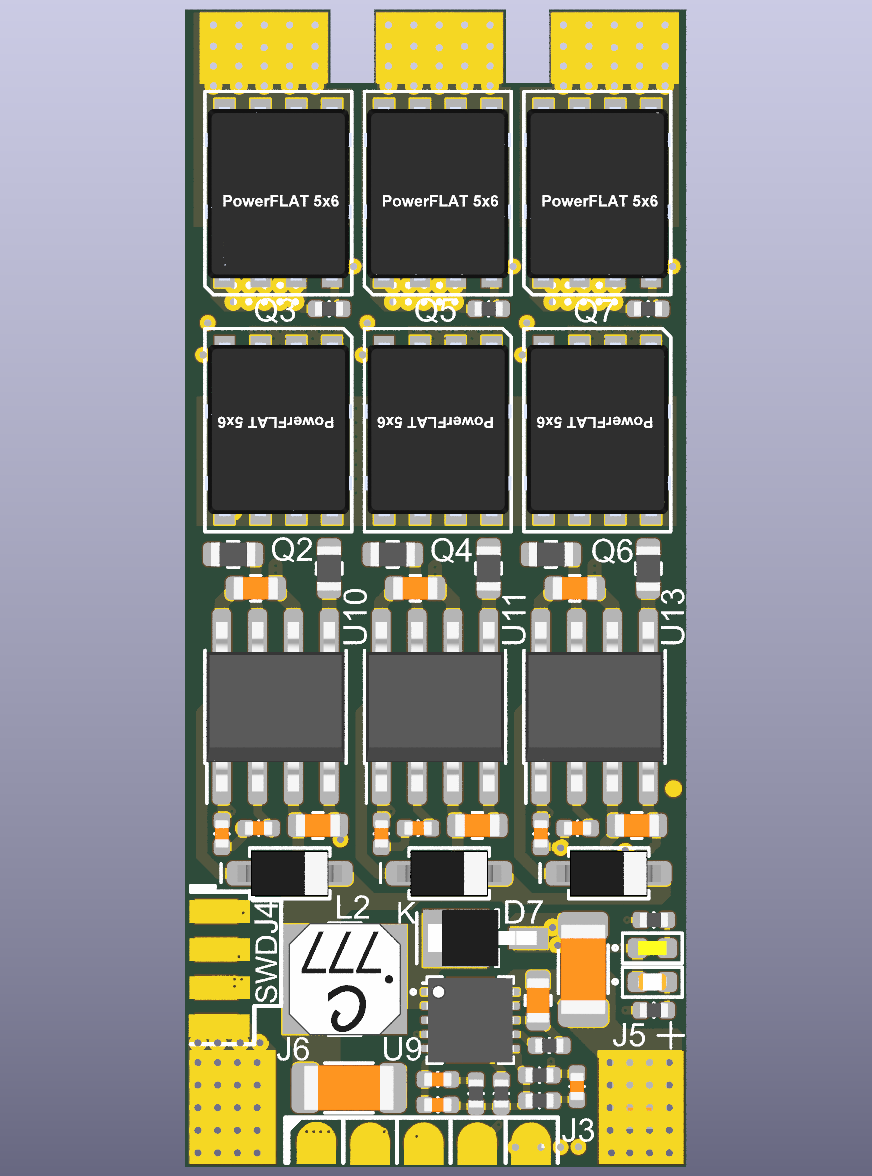
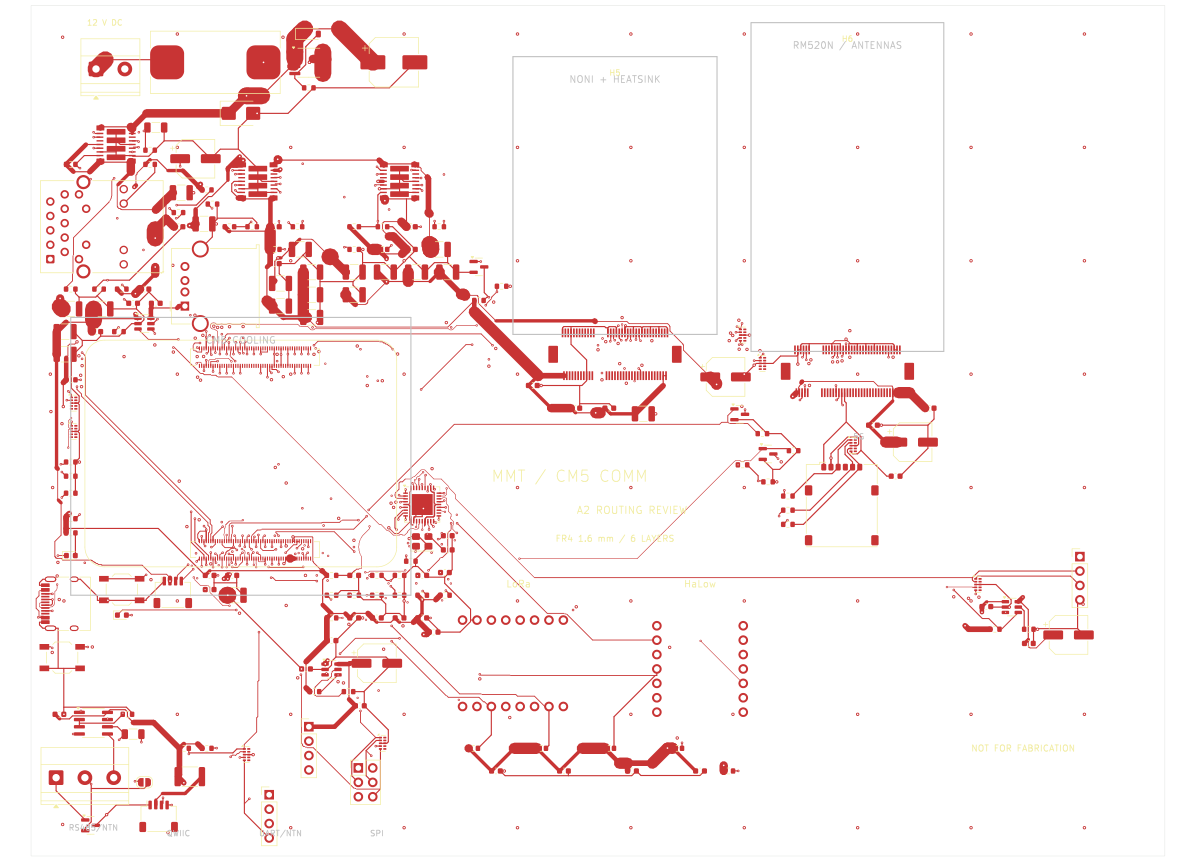
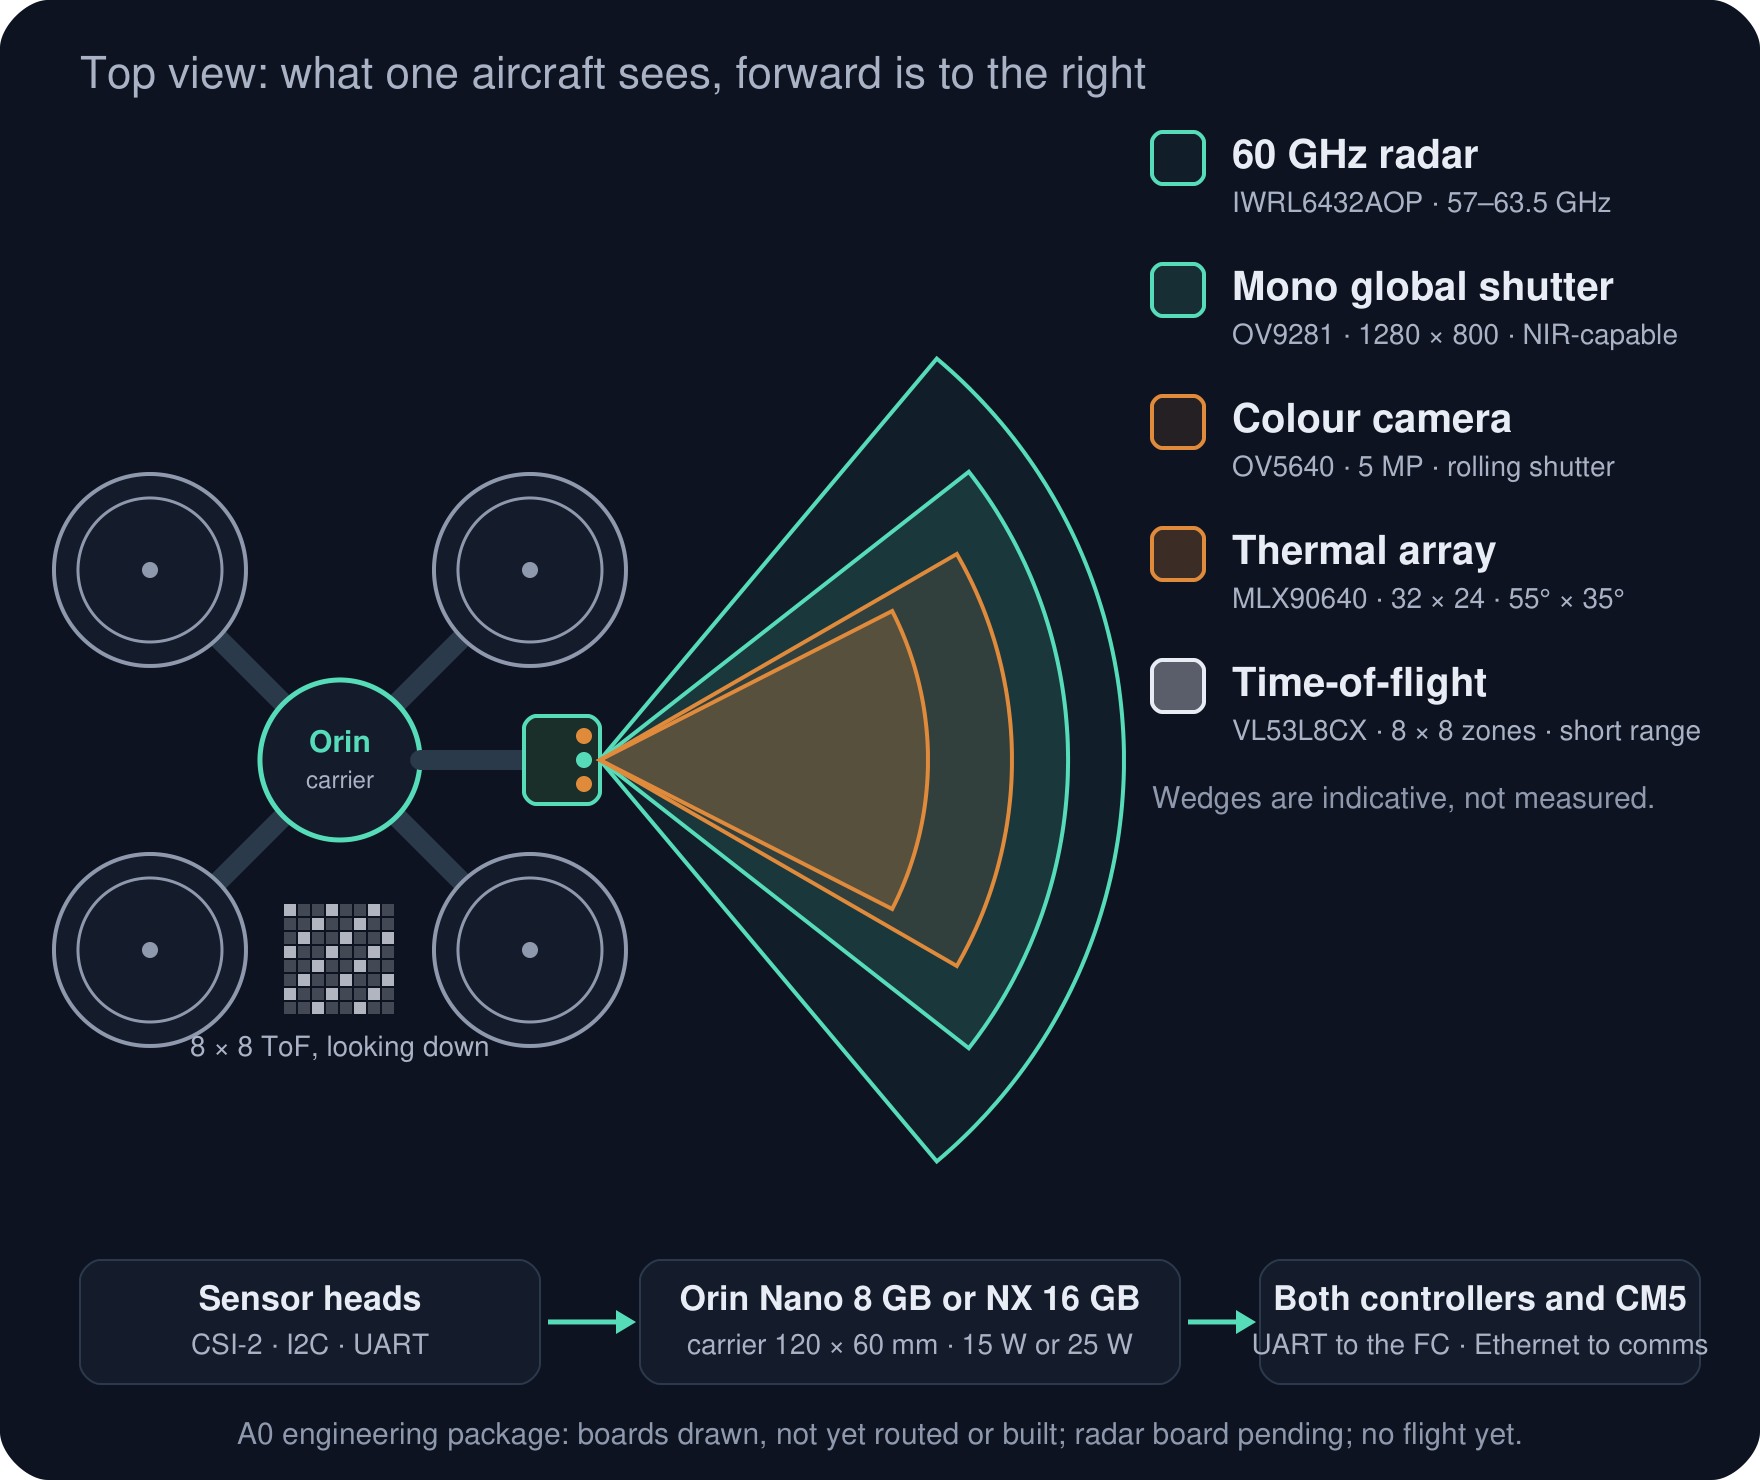
PCB layouts and concept illustrations show design work. Physical assembly and platform qualification remain separate.
04 / HARDWARE + OS
UNO Q status updated · 18 November 2026
| Target | Intended role | Current evidence | Still to establish |
|---|---|---|---|
| Arduino UNO Q | Split compute / controller research | Native Aevon port complete | Vehicle integration & control qualification |
| Raspberry Pi CM5 | Aevon reference · Aerqora communications | Scoped RAM evidence | Vehicle integration pending |
| STM32 controllers | Flight / motion-control candidates | Target-specific work | Control firmware & timing qualification |
| NVIDIA Orin | Aerqora perception compute | Engineering package | Native Aevon support not established |
Native Aevon ports are complete on UNO Q’s QRB2210 application processor and STM32U585 MCU. The application-processor image is installed and running with native storage and inference services. Aircraft integration and control qualification remain separate work.
05 / DEVELOPMENT PATH